RoboParty Unveils RP1, the World's First Full-Stack Open-Source Humanoid Robot
News related to:RoboParty · 2 min read
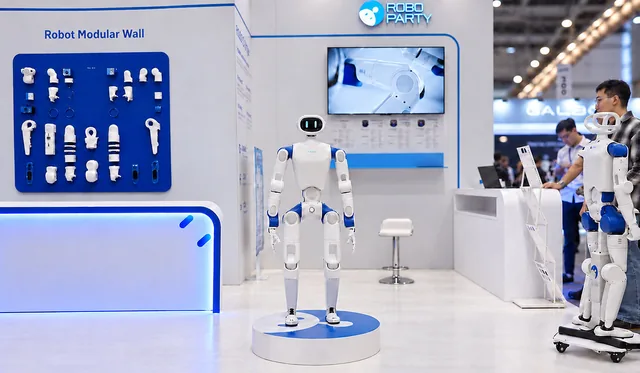
PITTSBURGH, Oct. 3, 2026 /CourierPR/ -- On September 28, 2026, RoboParty publicly unveiled RP1 (ROBOTO 01) at the International Conference on Intelligent Robots and Systems (IROS) 2026, marking the robot's global debut. This event underscores the company's commitment to advancing the field of humanoid robotics through open-source innovation.
RP1 stands out as the world's first high-performance full-stack open-source bipedal humanoid robot, designed for researchers, educators, robotics developers, and embodied AI teams. The robot's dynamic stability and robust recovery capabilities were showcased during an interactive demonstration at the company's booth. Visitors were able to push and kick RP1, which quickly adjusted its posture and regained balance, demonstrating its advanced body performance and system-level robustness.
At the heart of RP1's functionality is PartyOS, RoboParty's open R&D foundation for humanoid robotics. This platform integrates UFO, a training framework that discovers humanoid motor skills through unsupervised reinforcement learning. UFO supports skill transitions, disturbance recovery, and fall recovery without relying on predefined motion trajectories. The robot's peak joint torque of up to 160 N•m is built on in-house-developed Romomo actuator modules and a real-time motion-control system, ensuring precise and efficient operation.
RoboParty emphasizes the "full-stack open source" approach, which extends beyond releasing mechanical files. The company plans to progressively open its motion-control systems, simulation environments, software development kits (SDKs), training tools, and the PartyOS development foundation. This initiative aims to enable developers to participate from hardware and low-level control to model training and deployment.
RP1 builds on the validated open-source robot body and workflow of RPO (ROBOTO ORIGIN), which was launched in January 2026 and has garnered more than 2,500 GitHub stars. The robot also incorporates the dexterous RP Hand, with PartyOS evolving across humanoid locomotion, perceptual interaction, whole-body manipulation, and autonomous intelligent humanoids. Core team members of RoboParty have studied at prestigious institutions such as Tsinghua University's Yao Class, Peking University's Zhi Class, Harbin Institute of Technology, Stanford University, Carnegie Mellon University, and Zhejiang University.
RoboParty has built a global community of more than 5,000 developers. The company plans to announce further details of RP1's open-source roadmap in October 2026, with broader software and hardware releases and a mass-production program to follow later in the fourth quarter.